EgoSense H6 Head-Mounted 6-Camera Data Collection Device
Overview
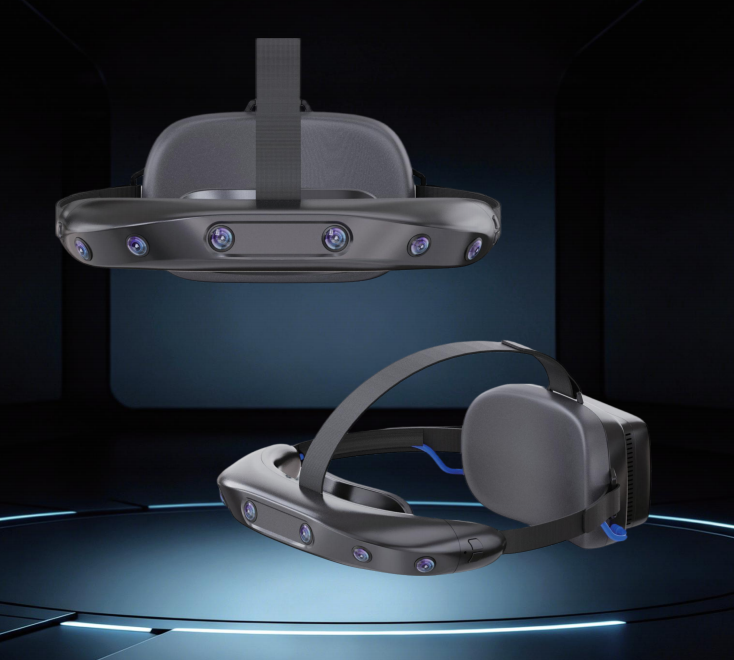
EgoSense H6 is a head-mounted, six-camera egocentric (first-person) data collection device developed by SENSING. It combines a front-facing stereo pair with two mono cameras on each side, for a total of six global shutter cameras covering a 270° combined field of view. A 6-axis IMU and microphones are built in, so the wearer's first-person view, head pose and audio are recorded in sync.
Data is recorded offline in MCAP format to the built-in Micro SD card, so no computer is needed while collecting. The Windows host software EGOTool provides live preview and recording control, and recordings can be played back directly in Foxglove Studio.
Fixed-camera and motion-capture labs cannot see hand details and are detached from real environments; robot teleoperation is costly and slow; simulated data suffers from the sim-to-real gap. EgoSense H6 is a lightweight wearable that takes data collection into real homes, factories, hospitals and shopping malls, delivering first-person perspective, multi-sensor synchronization and scalability at the same time.
Key Features
- First-person view, just like the human eye: records what the wearer actually sees, preserving hand-eye coordination and perception-decision behavior.
- Six global shutter cameras, 270° ultra-wide coverage: a front stereo pair plus two mono cameras per side, with no rolling-shutter distortion during motion.
- Multi-modal synchronization: images, IMU (200 Hz) and microphone audio are captured together; cameras support internal and external trigger synchronization.
- Wear and go, offline recording: battery powered with about 3 hours of runtime, recording straight to the Micro SD card — no camera rigs or dedicated venue required.
- Open data format: recordings are
.mcapfiles with H.265 video, readable in Foxglove Studio and easy to integrate into your own data pipeline. - Customizable: the complete device, main board and cameras can all be customized.
Applications
- Embodied AI data collection: capture real manipulation processes from a first-person view as high-quality training data for imitation learning and world models.
- Humanoid robot training: collect human demonstrations and visual data for robot skill learning.
- Multi-modal perception research: synchronized analysis of vision, inertial and audio data.
- Behavior analysis: record real-world operating procedures and habits.
Product Appearance
| Front | Side |
|---|---|
 |  |
Key Specifications
| Category | Item | Value |
|---|---|---|
| Physical | Dimensions | 268 × 223 × 92 mm |
| Weight | 350 g | |
| Battery runtime | About 3 hours | |
| Storage | 256 GB (Micro SD card) | |
| Connectivity | Wi-Fi, USB Type-C | |
| Output data | Images | RGB images (6 channels) |
| Inertial data | IMU data | |
| Audio | Microphone audio | |
| Recording format | .mcap (H.265 video) | |
| Cameras | Number of cameras | 6 (front stereo pair + 2 mono cameras per side) |
| Resolution | 1600 × 1300 | |
| Frame rate | 30 fps (60 fps optional) | |
| Combined FOV | 270° | |
| Shutter | Global shutter | |
| IMU | Type | 6-axis |
| Sample rate | 200 Hz |
Hardware Specifications
Main Controller
| Category | Item | Value |
|---|---|---|
| SoC | Platform | Rockchip RK3588 |
| CPU | 4 × ARM Cortex-A76 + 4 × ARM Cortex-A55 | |
| VPU | Encoding up to 8K@30fps, H.265 / H.264 | |
| ISP | Image processing up to 32MP@30fps | |
| Memory & storage | DDR | 4 GB |
| eMMC | 32 GB | |
| Micro SD | Up to 256 GB, write speed > 50 MB/s | |
| Interfaces | Camera | 3 × MIPI CSI-2 (4 lanes) |
| USB | 1 × Type-C | |
| Speaker | 2 channels, PDM / I2S | |
| Microphone | 2 channels, PDM / I2S | |
| Wireless | Wi-Fi 6 (AP + STA modes, ≥ 100 Mbps uplink/downlink), Bluetooth 5.3 | |
| Power | Battery | 10000 mAh, snap-on magnetic battery |
| Charging port | Type-C with PD fast charging | |
| Electrical | Typical power consumption | < 10 W |
| Operating temperature | -20 ~ 60 ℃ | |
| Mechanical | Cooling | Fan |
| Ingress protection | IP52 | |
| Buttons & indicators | Record button | Start / stop recording (with voice prompt) |
| Volume + / - | Adjust the prompt volume | |
| LED indicator | Shows power and recording status |
Camera Module
| Item | Value |
|---|---|
| Sensor | OG02B10 |
| Resolution | 1600 × 1300 |
| Frame rate | 30 fps |
| Shutter | Global shutter |
| Output format | RAW color |
| Lens FOV | H160° × V130° |
| Power consumption | < 0.5 W |
| Intrinsics storage | EEPROM |
| Weight | < 30 g |
| Operating temperature | -10 ~ 60 ℃ |
| Synchronization | Internal and external trigger |
Software Architecture
EgoSense H6 runs Rockchip Linux. The software is organized into a driver layer and an application layer:
| Layer | Modules |
|---|---|
| Application | Data Storage, Time Sync, Viewer, Tools, HMI |
| Driver | Image sensor, SerDes, IMU, audio, communication and storage configuration |
| Operating system | Rockchip Linux |
Companion Software
| Software | Platform | Purpose |
|---|---|---|
| EGOTool host software | Windows | Connect to the device, six-channel live preview, recording control, encoding settings, capture metadata entry, device status |
| Foxglove Studio | Windows / macOS / Linux | Open and play back .mcap recordings, view images and IMU data |
For step-by-step instructions, see the EgoSense H6 User Manual.
Data Format: MCAP
EgoSense H6 recordings use the MCAP format. MCAP is an open-source, modular container file format for robotics and autonomous driving, created by Foxglove to record multiple sensor streams — camera images, IMU data and more — packed by timestamp into a single file for playback and analysis.
- Similar in purpose to ROS bags (
.bag/.db3), but with better read/write performance and broader language support (official SDKs for C++ / Python / Rust / Go). - The default storage format of ROS 2 rosbag2, and natively supported by Foxglove Studio.
- One
.mcapfile holds everything the device saw and sensed during a session, ready for algorithm debugging, data labeling and issue reproduction.
EgoSense H6 recordings contain the following topics:
| Topic | Message type | Description |
|---|---|---|
/camera/middle-1/h265, /camera/middle-2/h265 | foxglove.CompressedVideo | Front stereo cameras (H.265) |
/camera/left-1/h265, /camera/left-2/h265 | foxglove.CompressedVideo | Two left-side cameras (H.265) |
/camera/right-1/h265, /camera/right-2/h265 | foxglove.CompressedVideo | Two right-side cameras (H.265) |
/imu | foxglove.IMU | 6-axis IMU data |
Sample recording data is available under User Manual · Downloads.
Customization
SENSING offers customization of the complete EgoSense device, main board and cameras:
- Camera count: 2 / 3 / 4 / 5 / 6-camera EgoSense configurations built from mono and stereo cameras.
- Camera options: OG02B10, AR0234, ISX031, OV9281 and more, in mono and stereo form factors.
- Software support: drivers, applications and ISP tuning services.
- Combined solutions: works with UMI grippers, wrist units or a backpack collection system for synchronized head and hand data capture.
Please contact our sales team for customization.
Contact Us
- Sales: Sales@sensing-world.com
- Technical support: support@sensing-world.com
- Phone: +86-755-28990915
- Website: www.sensing-world.com
Business hours: Monday - Friday, 9:00 AM - 6:00 PM (GMT+8)